Autonomously Reconfigurable Miniature Robots
Miniature, Modular, and Legged Robot Systems that Learn Autonomous Configurations with Artificial Intelligence
Search and rescue and inspection of hazardous spaces need robots that fit through narrow gaps. Miniature legged robots can reach these spaces, but building a separate robot for every task is costly.
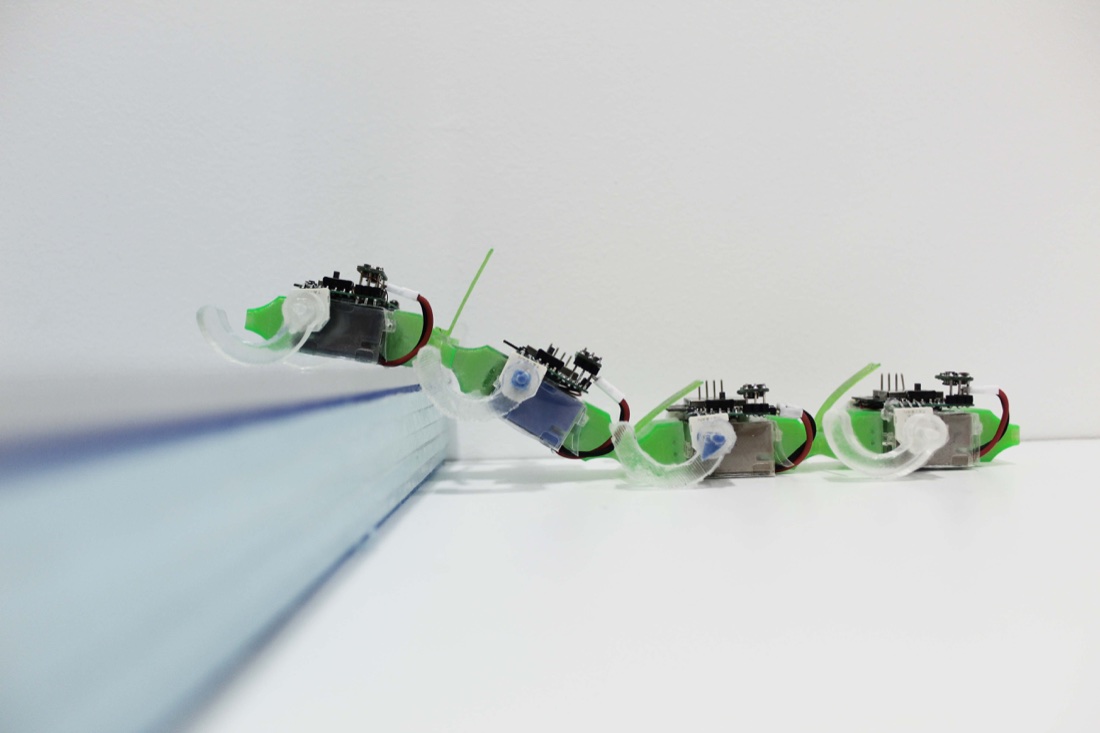
This project extends ReLMBot with new task specific modules and teaches the robot to choose its own module combination. The choice is learned in simulation and then tested on the physical robot.
This project extends ReLMBot with task specific modules: an optical camera module, an infrared camera module for low visibility, and a tail module for climbing and balance. Digital twins of the modules are built in MuJoCo, and deep reinforcement learning selects the module combination for each task, such as moving through narrow gaps or scanning in darkness. The learned policies are then tested on the physical robot.
Other projects
 Bilkent Miniature
Robotics Lab
Contact
Assoc. Prof. Dr. Onur Özcan
Department of Mechanical Engineering
Bilkent University
Bilkent, Çankaya, Ankara 06800 TURKEY
Reach us
onurozcan@bilkent.edu.tr
Phone: +90-312-290-2893
Fax: +90-312-266-4126
Funding
Horizon Europe (TWIST), BİLGEM, TÜBİTAK 1001, 1003, 2232, 3001, 3501